Projects / VEHICLES
Thrust Vector
Control Concept
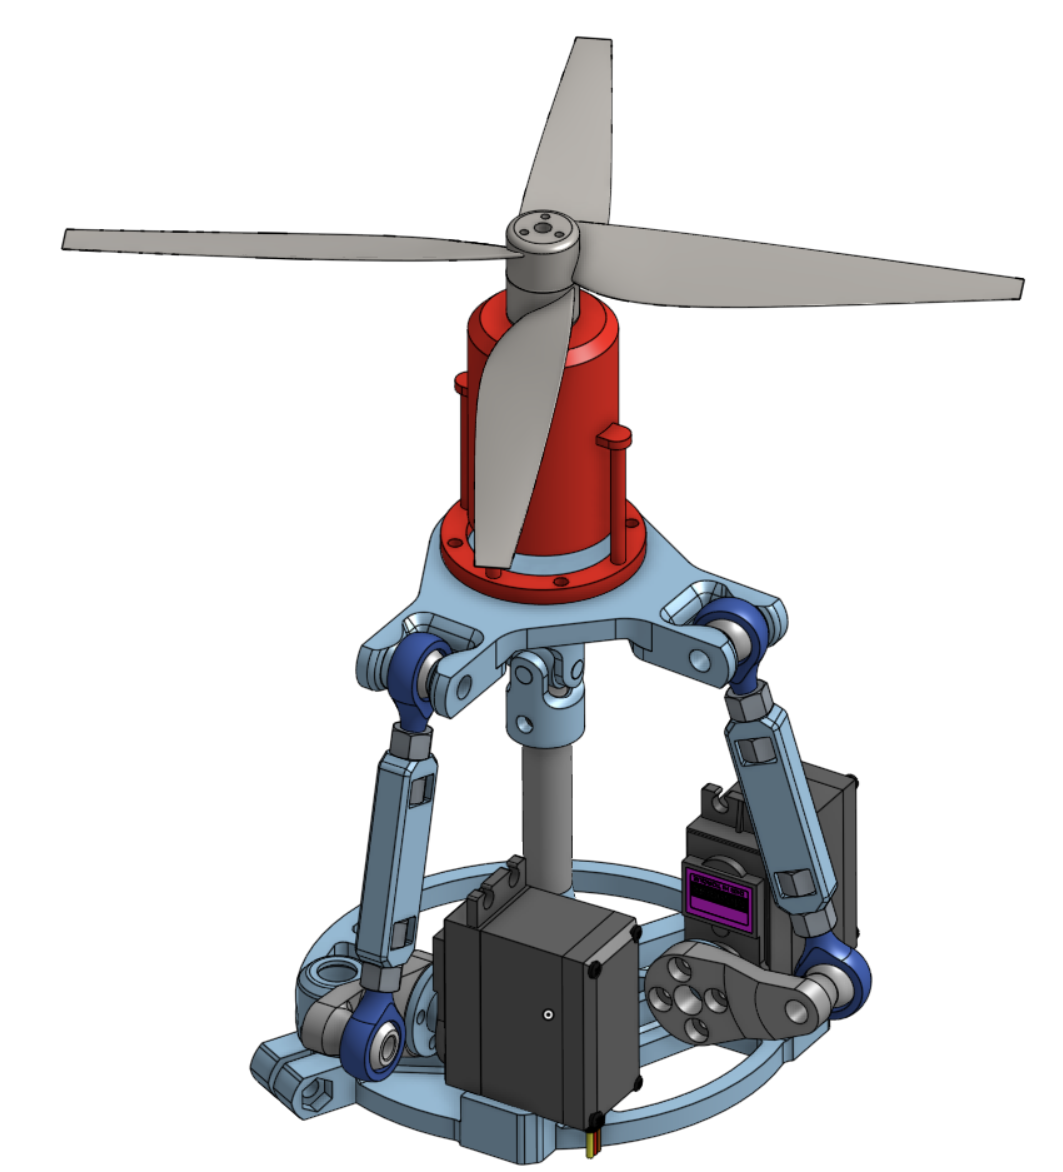
A controls test hopper drone
A controls test hopper drone
The Thrust Vector Control Concept is a testbed that allows us to validate our control algorithms in a physical environment. As APRL begins to develop projects and vehicles that require more than just passive control, the ability to test and validate active control systems becomes increasingly important.
TVC^2 provides a platform for bridging the gap between simulation and physical hardware.Control algorithms can be developed and validated in MATLAB and Simulink before being implemented on the Teensy and tested on the physical system.
Working with a physical vehicle allows us to evaluate the effects or real world factors such as sensor noise, actuator response and control latency, This allows us to develop and refine robust control systems that can eventually be applied to vehicles requiring active stabilization and thrust vector control.